Section 4.3 Algebra of Transformations

Subsection 4.3.1 Explore

Definition 4.3.1 Translation.

An transformation \(T\) is a translation if and only if there exists a non-zero constant vector \(\vec{v}\) such that \(T(P)-P=\vec{v}\) for all points \(P.\)

Definition 4.3.2 Rotation.

An transformation \(T\) is a rotation if and only if there exists a fixed point \(C\) and constant angle \(\alpha\) such that \(m\angle PCT(P) = \alpha \) and \(\|\overline{CP}\| = \|\overline{CT(P)}\|\) for all points \(P\)

Definition 4.3.3 Reflection.

An transformation \(T\) is a reflection if and only if there exists a fixed line \(\ell\) such that the line perpendicular to \(\ell\) through \(P\) contains \(T(P)\) and the distances from \(P\) and \(T(P)\) to the \(\ell\) are equal.

Proof.

Translation: Let \(T\) be a translation. By definition, there exists a vector \(\mathbf{v}\neq\mathbf{0}\) such that
\begin{equation*} T(P)-P=\mathbf{v}=T(Q)-Q. \end{equation*}
This implies that there exists some vector \(\mathbf{u}\) so that
\begin{equation*} T(P)-T(Q) = P-Q=\mathbf{u}. \end{equation*}
Taking the magnitude of \(\mathbf{u}\text{,}\) we get
\begin{equation*} ||T(P)-T(Q)||=||P-Q||=||\mathbf{u}||. \end{equation*}
By definition, \(T\) is an isometry.

Proof.

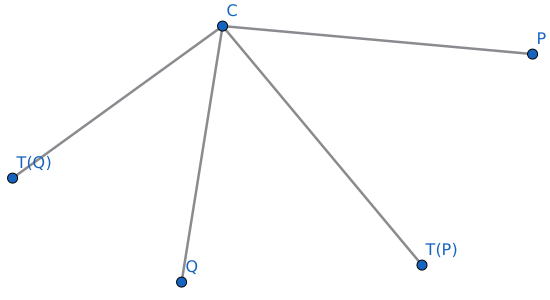
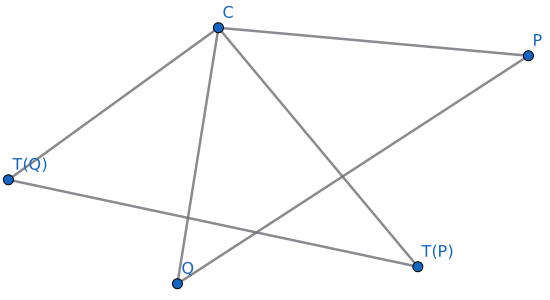
We have two points \(P\) and \(Q\) that is rotated around the point \(C\) making the new points \(T(P)\) and \(T(Q)\text{.}\)
By the definition of rotation, \(m\angle PCT(P) = m\angle QCT(Q)\text{.}\) We can make triangles \(\triangle T(Q)CT(P)\) and \(\triangle QCP\)
With angle addition postulate, \(m\angle T(Q)CT(P) = m\angle T(Q)CQ + m\angle QCT(P)\) and \(m\angle QCP = m\angle QCT(P) + m\angle T(P)CP\text{.}\) Since \(m\angle T(Q)CQ = m\angle T(P)CP\text{,}\) we have that \(\angle T(Q)CT(P) \cong \angle QCP\) and by SAS, \(\triangle T(Q)CT(P) \cong \triangle QCP\text{,}\) making \(\overline{T(Q)T(P)} \cong \overline{QP}\text{.}\) Meaning their distance are equal making it an isometry.

Proof.

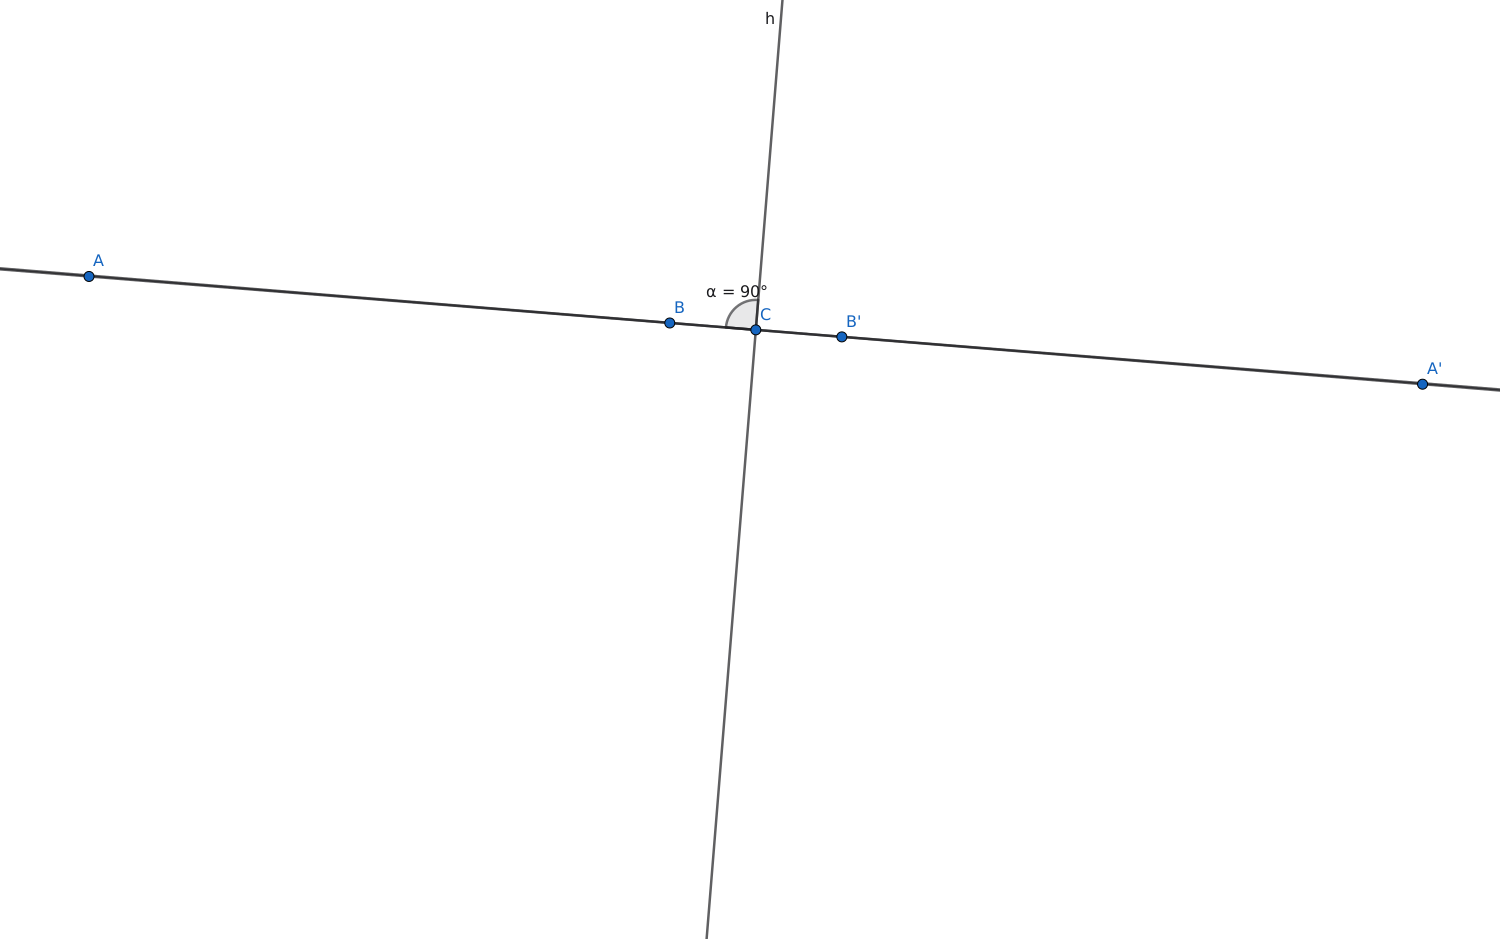
Take points \(A,\ B\) and a reflection \(T\) about the line \(h\text{.}\) We then have two cases:
Case 1: \(A\) and \(B\) are colinear.
Then, calling \(h\cap\overleftrightarrow{AB}=C\text{,}\) we have in the image above and from the definition of a reflection \(\overline{AC}=\overline{A^{\prime}C}\text{,}\) \(\overline{BC}=\overline{B^{\prime}C}\text{,}\) so:
\begin{gather*} |\overline{AB}|=|\overline{AC}|-|\overline{BC}| = \\ |\overline{A^{\prime}C}|-|\overline{B^{\prime}C}| =\\ |\overline{A^{\prime}B^{\prime}}| \end{gather*}
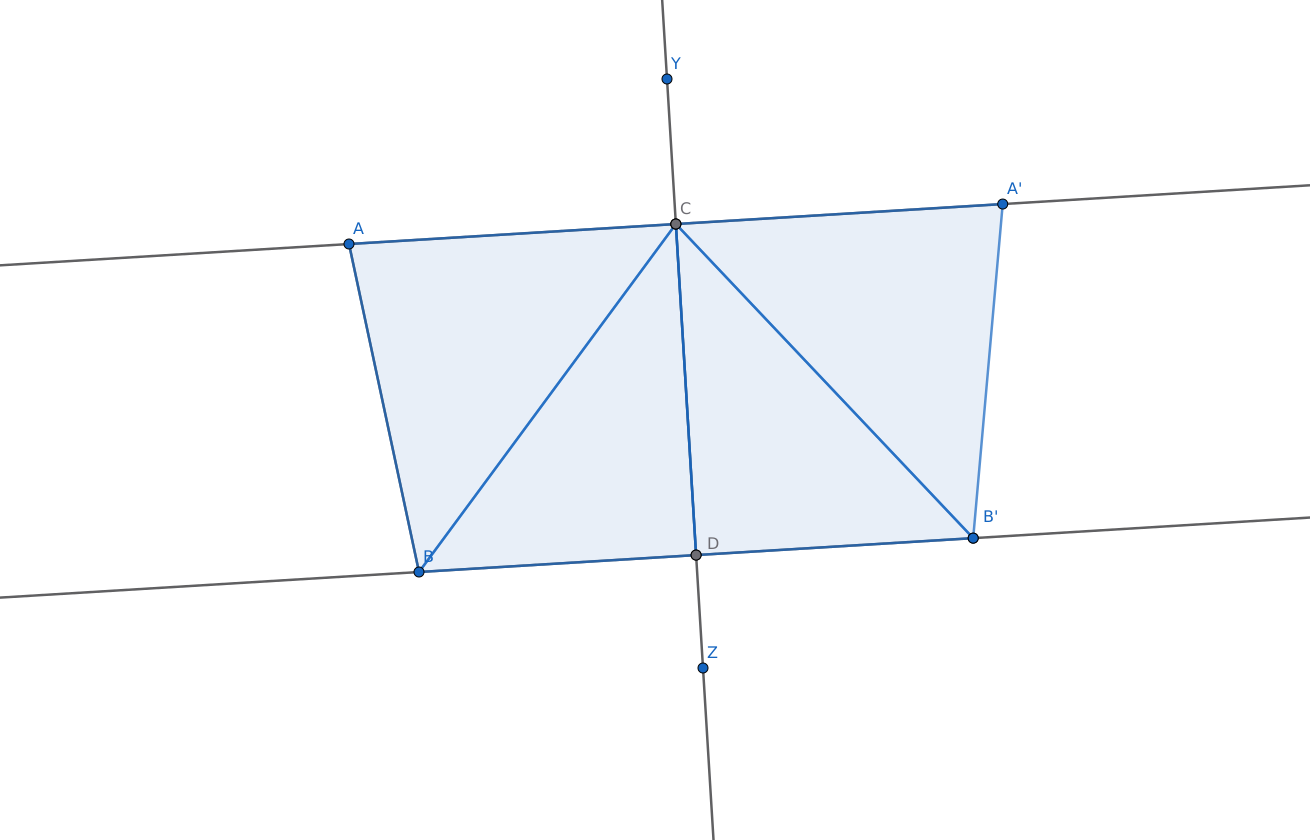
Case 2: \(A\) and \(B\) are not colinear.
By the definition of a reflection, \(|\overline{AC}|=|\overline{A^{\prime}C}|\) and \(|\overline{BD}|=|\overline{B^{\prime}D}|\text{.}\) We know from the definition of a reflection that \(\overline{AA^{\prime}},\ \overline{BB^{\prime}}\perp\overline{CD}\text{.}\) From these, we know that \(\triangle{BCD}\cong\triangle{B^{\prime}CD}\) by SAS. Hence \(|\overline{BC}|=|\overline{B^{\prime}C}|\text{.}\) We can also know that \(\angle{ACB}\cong\angle{A^{\prime}CB^{\prime}}\) from the following:
\begin{align*} 90= \amp m(\angle{ACD})\\ = \amp m(\angle{ACB})+m(\angle{BCD}) \end{align*}
and
\begin{align*} 90= \amp m(\angle{A^{\prime}CD})\\ = \amp m(\angle{A^{\prime}CB^{\prime}})+m(\angle{B^{\prime}CD}). \end{align*}
These two give:
\begin{equation*} m(\angle{ACB})+m(\angle{BCD})=m(\angle{A^{\prime}CB^{\prime}})+m(\angle{B^{\prime}CD}). \end{equation*}
Applying our triangle congruence shows:
\begin{equation*} m(\angle{ACB})=m(\angle{A^{\prime}CB^{\prime}}). \end{equation*}
Therefore \(\triangle{ACB}\cong\triangle{A^{\prime}CB^{\prime}}\) by SAS.
Hence \(\overline{AB}\cong\overline{A^{\prime}B^{\prime}}\) and we have proven that reflections are isometries.

Checkpoint 4.3.5.

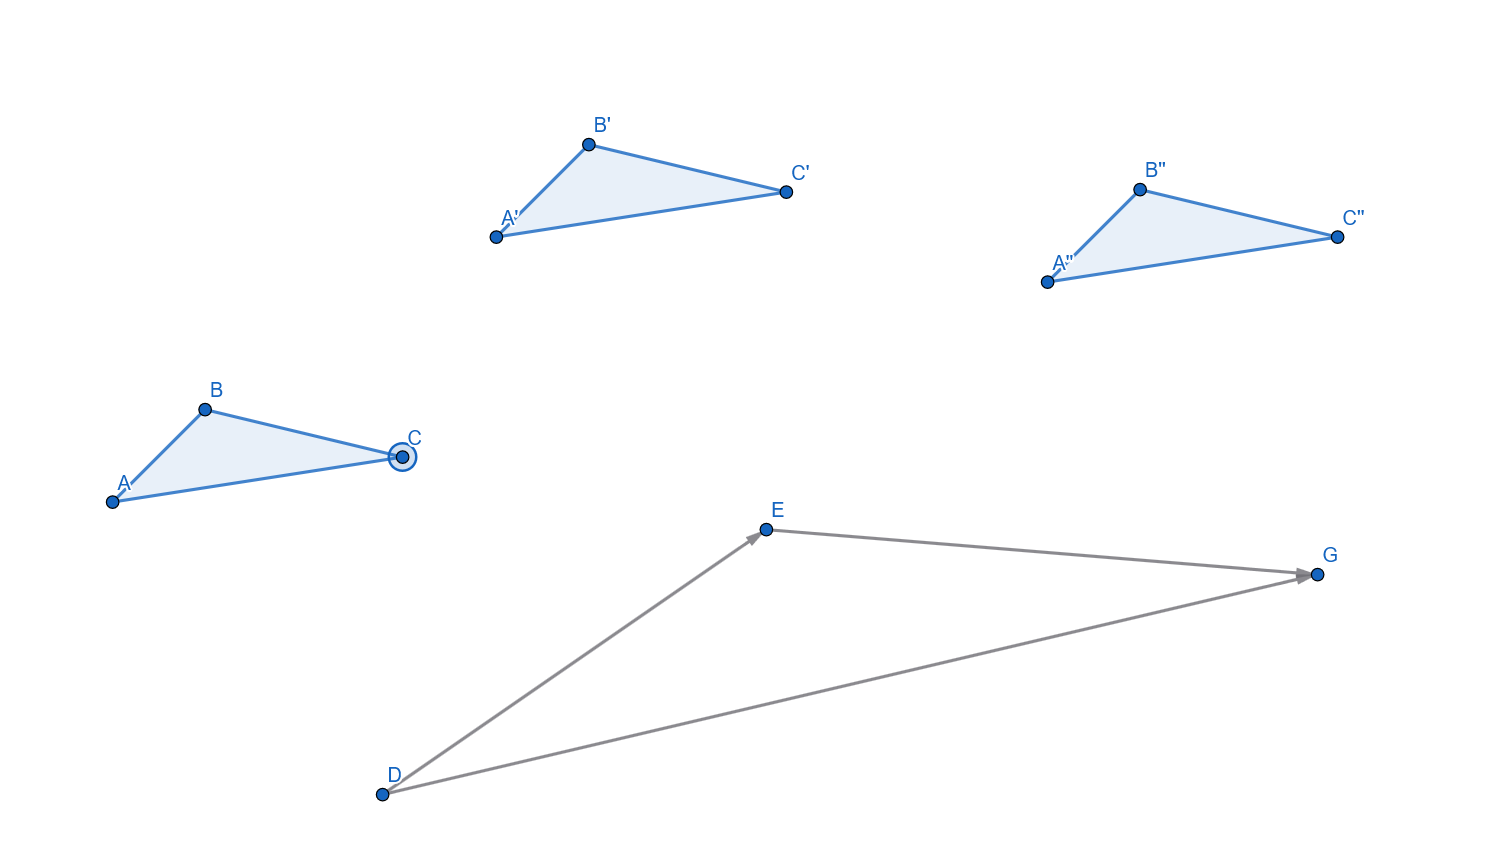
Draw an arbitrary triangle \(ABC.\) Draw the result \(\triangle A'B'C'\) of some translation. Draw the result \(\triangle A''B''C''\) of some translation applied to \(\triangle A'B'C'.\) Determine which type of isometry would transform \(\triangle ABC \) to \(\triangle A''B''C''.\)
Solution.
The transformation from \(\triangle ABC\) to \(\triangle A''B''C''\) would require a translation with the vector as pictured (vector addition). There is a special case when the translation vector for \(\triangle ABC\) to \(\triangle A'B'C'\) is \(\vec{v}\) and the translation vector for \(\triangle A'B'C'\) to \(\triangle A''B''C''\) is \(-\vec{v}\text{.}\) The vector for the transformation from \(\triangle ABC\) to \(\triangle A''B''C''\) is the zero vector and the transformation is the identity.

Checkpoint 4.3.6.

Complete the following table of composition of isometries.

Checkpoint 4.3.7.

What is the composition of a reflection and a rotation?
Solution.
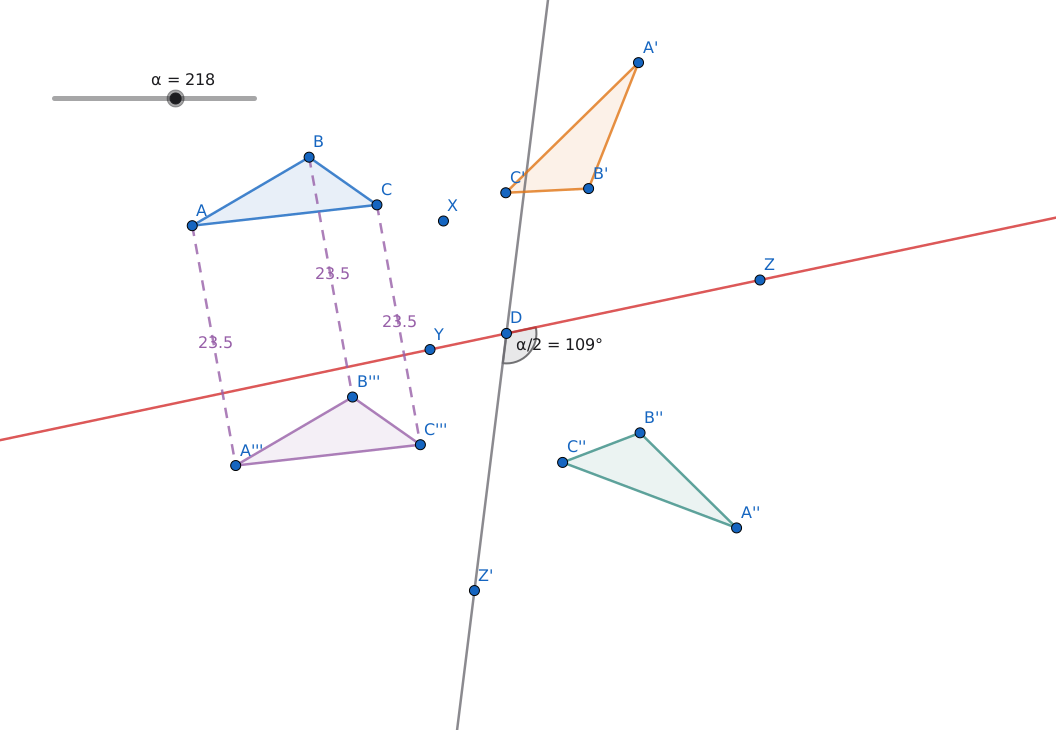
First, rotate \(\triangle ABC\) about point \(X\) with rotation angle \(\alpha\) counterclockwise to obtain the rotated triangle \(\triangle A'B'C'\text{.}\) Then, reflect \(\triangle A'B'C'\) across line \(\overleftrightarrow{YZ}\) to get triangle \(\triangle A''B''C''\text{.}\) To get from the original triangle \(\triangle ABC\) to the result under the two isometries \(\triangle A''B''C''\text{,}\) we must notice a few things.
First, we cannot get from \(\triangle ABC\) to \(\triangle A''B''C''\) from a single translation since it is not always the case that \(||\overline{AA''}||=||\overline{BB''}||\text{.}\) Second, we cannot get from the original triangle to the resultant triangle with a single reflection since the perpendicular bisector of \(\overline{AA''}\) is not the perpendicular bisector of \(\overline{BB''}\text{.}\) Third, we cannot get from the first triangle to the final triangle with a single rotation since the chirality of each do not match. That is, the vertices of the first triangle are ABC clockwise but are \(A''C''B''\) on the final triangle.
To get from the final triangle to the initial triangle, we first reflect \(\triangle A''B''C''\) across line \(\overleftrightarrow{DZ'}\text{,}\) where \(m\angle ZDZ'=\alpha/2\) clockwise. Then, we translate up the resultant triangle \(\triangle A'''B'''C'''\) to get back to the initial triangle \(\triangle ABC\text{.}\)
Checkpoint 4.3.8.

What is the composition of a reflection and a translation?
Solution.
Doing the isometries Translation then Rotation is equivalent to doing a single rotation around a different point
From observations in GeoGebra, we can easily show that unless the reflecting line is perpendicular to the translating vector, the translation and reflection do not commute.
Table 4.3.9. Composition of Isometries
Translate Reflect Rotate
Translate
Reflect
Rotate

Subsection 4.3.2 Answer and Explain

Checkpoint 4.3.10.

How many isometry types are there?

Checkpoint 4.3.11.

How many isometry types are needed to generate all isometry types?

Checkpoint 4.3.12.

How many isometries are needed to generate all isometries?